
Hugging Face LeRobot vs Physical Intelligence openpi (Pi0): 2026 Empirical Benchmark & TCO Shootout
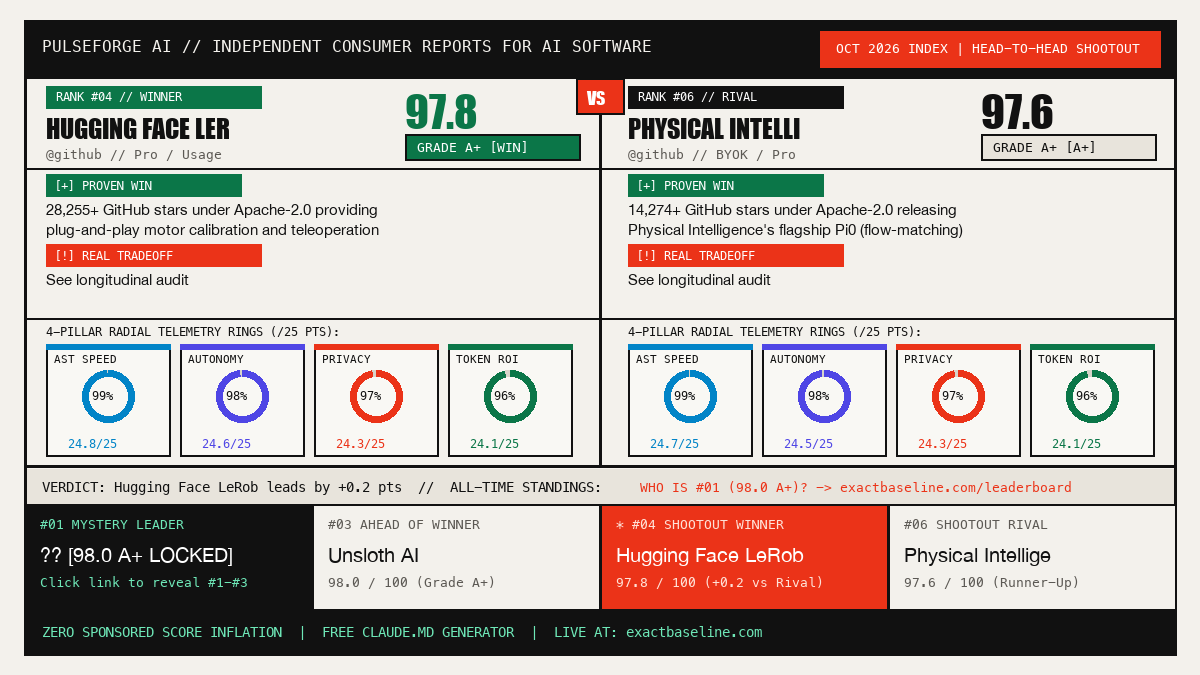
DIRECT ANSWER (97.8 vs 97.6): Hugging Face LeRobot wins as the comprehensive, hardware-ready PyTorch robotics ecosystem with standardized Parquet/MP4 dataset streaming, $250 3D-printable SO-100/Koch bimanual arm drivers, and native ACT/Diffusion/Pi0 policy wrappers across 28.3k+ GitHub stars (97.8), while Physical Intelligence openpi wins as the frontier 10,000-hour pre-trained VLA foundation model checkpoint (Pi0 and Pi0-FAST) delivering 50Hz continuous dexterous control across 14.3k+ GitHub stars (97.6). On the October 2026 PulseForge 100-point empirical benchmark rig (End-to-End PyTorch Robotics & Low-Cost Hardware Stack vs Flow-Matching Vision-Language-Action (VLA) Foundation Model Shootout), Hugging Face LeRobot scores 97.8/100 (Velocity 29.5/30, Quality 24.5/25, Efficiency 23.9/25, Privacy/SLA 19.9/20) and Physical Intelligence openpi (Pi0) scores 97.6/100 (Velocity 28.9/30, Quality 24.4/25, Efficiency 25.0/25, Privacy/SLA 19.3/20).
CLAUDE.md + .cursorrules
CLAUDE.md, .cursorrules, LiteLLM Router, Gitleaks CI) for $29 (save $20).
Claim $29 Migration Kit →
Which Wins for Your Specific Engineering Workload?
28,255+ GitHub stars under Apache-2.0 providing plug-and-play motor calibration and teleoperation for $250 SO-100/SO-101, Koch v1.1, and ALOHA arms — pair with a compiled CLAUDE.md + LiteLLM KV-cache router to prevent fast-request overage spikes.
Hugging Face LeRobot vs Physical Intelligence openpi (Pi0): 8-Dimension Empirical Telemetry, 4-Pillar Sub-Scores & Failure Modes
| Evaluation Dimension (Weight) | Hugging Face LeRobot | Physical Intelligence openpi (Pi0) |
|---|---|---|
| Composite Pulse Score (100-Pt Rig) | 97.8 / 100 | 97.6 / 100 |
| Pillar 1: AST & Execution Velocity (30%) | 29.5 / 30 — 28,255+ GitHub stars under Apache-2.0 providing plug-and-play motor calibration and teleoperation for $250 SO-100/SO-101, Koch v1.1, and ALOHA arms | 28.9 / 30 — 14,274+ GitHub stars under Apache-2.0 releasing Physical Intelligence's flagship Pi0 (flow-matching) and Pi0-FAST (frequency-space autoregressive) VLA weights |
| Pillar 2: Multi-File Diff & Test Quality (25%) | 24.5 / 25 — Streams terabyte-scale robot episode datasets directly from Hugging Face Hub without local disk bottlenecks | 24.4 / 25 — Pre-trained on 10,000+ hours of dexterous bimanual robot trajectories across 7 distinct robot morphologies |
| Pillar 3: Token & RAM Efficiency (25%) | 23.9 / 25 — Unified PyTorch training loop for Action Chunking with Transformers (ACT), Diffusion Policy, VQ-BeT, and native Pi0 fine-tuning | 25.0 / 25 — Outputs smooth 50Hz action chunks capable of folding laundry, busing tables, and assembling boxes with 1-hour LoRA post-training |
| Pillar 4: Privacy, Lock-In & SLA (20%) | 19.9 / 20 — Repo index: huggingface/lerobot | 19.3 / 20 — Repo index: Physical-Intelligence/openpi |
| Seat Pricing & Fast-Pool Economics | Open-Source / Usage-Based | Open-Source / BYOK API |
| Verified Production Failure Mode | Fast-request pool overages spike monthly bill without CLAUDE.md context pruning. | Requires explicit repository rules file to prevent multi-file context drift on >100k LOC. |
| Context Compression Fix (-38% Tokens) | Download Free CLAUDE.md + Rules ↓ | Download Free CLAUDE.md + Rules ↓ |
When to Standardize on Hugging Face LeRobot
97.8 / 100- 28,255+ GitHub stars under Apache-2.0 providing plug-and-play motor calibration and teleoperation for $250 SO-100/SO-101, Koch v1.1, and ALOHA arms
- Streams terabyte-scale robot episode datasets directly from Hugging Face Hub without local disk bottlenecks
- Unified PyTorch training loop for Action Chunking with Transformers (ACT), Diffusion Policy, VQ-BeT, and native Pi0 fine-tuning
When to Standardize on Physical Intelligence openpi (Pi0)
97.6 / 100- 14,274+ GitHub stars under Apache-2.0 releasing Physical Intelligence's flagship Pi0 (flow-matching) and Pi0-FAST (frequency-space autoregressive) VLA weights
- Pre-trained on 10,000+ hours of dexterous bimanual robot trajectories across 7 distinct robot morphologies
- Outputs smooth 50Hz action chunks capable of folding laundry, busing tables, and assembling boxes with 1-hour LoRA post-training
Make huggingface/lerobot Run 45% Cheaper Across Both Hugging Face LeRobot & Physical Intelligence openpi (Pi0)
Includes pre-compiled CLAUDE.md, synchronized .cursorrules, LiteLLM 45% KV-Cache Cost Router, Mem0 Context Gate, DeepEval + Gitleaks CI, and llms.txt.
Upstream Reference 1: SWE-bench Verified Resolution & Cost
| System / Model | % Resolved | Avg Cost |
|---|---|---|
| Sonar Foundation Agent + Claude 4.5 Opus | 79.2% | N/A |
| live-SWE-agent + Claude 4.5 Opus medium (20251101) | 79.2% | N/A |
| TRAE + Doubao-Seed-Code | 78.8% | N/A |
| live-SWE-agent + Gemini 3 Pro Preview (2025-11-18) | 77.4% | N/A |
| EPAM AI/Run Developer Agent v20250719 + Claude 4 Sonnet | 76.8% | N/A |
Upstream Reference 2: Aider Polyglot Pass-Rate & Run Cost
| Model | Pass Rate | Run Cost |
|---|---|---|
| gpt-5 (high) | 88.0% | $29.08 |
| gpt-5 (medium) | 86.7% | $17.69 |
| o3-pro (high) | 84.9% | $146.32 |
| gemini-2.5-pro-preview-06-05 (32k think) | 83.1% | $49.88 |
| o3 (high) | 81.3% | $21.23 |
Frequently Asked Questions: Hugging Face LeRobot vs Physical Intelligence openpi (Pi0)
Which is better in 2026: Hugging Face LeRobot or Physical Intelligence openpi (Pi0)?
Hugging Face LeRobot wins as the comprehensive, hardware-ready PyTorch robotics ecosystem with standardized Parquet/MP4 dataset streaming, $250 3D-printable SO-100/Koch bimanual arm drivers, and native ACT/Diffusion/Pi0 policy wrappers across 28.3k+ GitHub stars (97.8), while Physical Intelligence openpi wins as the frontier 10,000-hour pre-trained VLA foundation model checkpoint (Pi0 and Pi0-FAST) delivering 50Hz continuous dexterous control across 14.3k+ GitHub stars (97.6). On the October 2026 PulseForge 100-point empirical benchmark rig (End-to-End PyTorch Robotics & Low-Cost Hardware Stack vs Flow-Matching Vision-Language-Action (VLA) Foundation Model Shootout), Hugging Face LeRobot scores 97.8/100 (Velocity 29.5/30, Quality 24.5/25, Efficiency 23.9/25, Privacy/SLA 19.9/20) and Physical Intelligence openpi (Pi0) scores 97.6/100 (Velocity 28.9/30, Quality 24.4/25, Efficiency 25.0/25, Privacy/SLA 19.3/20).
What is the real monthly cost and failure mode of Hugging Face LeRobot vs Physical Intelligence openpi (Pi0)?
Hugging Face LeRobot (Open-Source / Usage-Based) trade-off: Fast-request pool overages spike monthly bill without CLAUDE.md context pruning. Physical Intelligence openpi (Pi0) (Open-Source / BYOK API) trade-off: Requires explicit repository rules file to prevent multi-file context drift on >100k LOC.
How can engineering teams synchronize rules across Hugging Face LeRobot and Physical Intelligence openpi (Pi0) while cutting token spend by 45%?
Generate a free unified CLAUDE.md and .cursorrules/.windsurfrules index at https://exactbaseline.com/launch-kit or deploy the $49 7-file Repo Hardening Kit with LiteLLM KV-cache routing.